Robotics graduate working across navigation, mechanisms and embedded control. I document the decisions behind a system, my contribution, and what I learned when it met the real world.
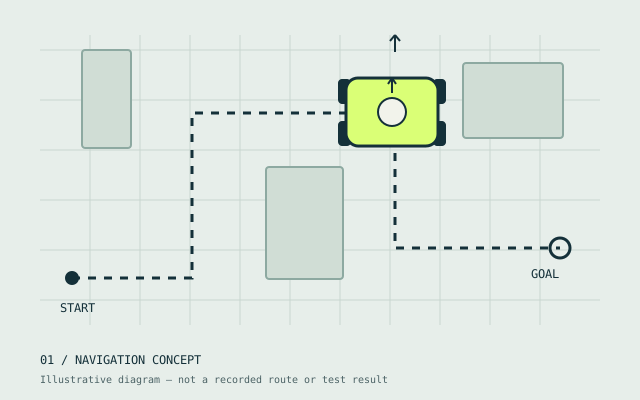
A student rover project exploring localisation and repeatable navigation in a changing indoor route.
ROS 2
Python
Lidar
Wheel encoders
Context
The team could drive the rover manually, but it lost track of its position when a wheel slipped or the corridor layout changed.
Objective
Connect localisation, route planning and motion control, then make the failure cases understandable to the next team.
My contribution
I integrated the encoder and lidar inputs, checked coordinate frames, and wrote a repeatable route procedure. Recorded runs helped separate localisation errors from controller tuning problems.
Outcome
The project handover included route recordings, configuration notes and examples of recovery failures. Reflective surfaces remained an open issue for the next iteration.
Case 02Design module
Adaptive gripper study
My role Mechanism design
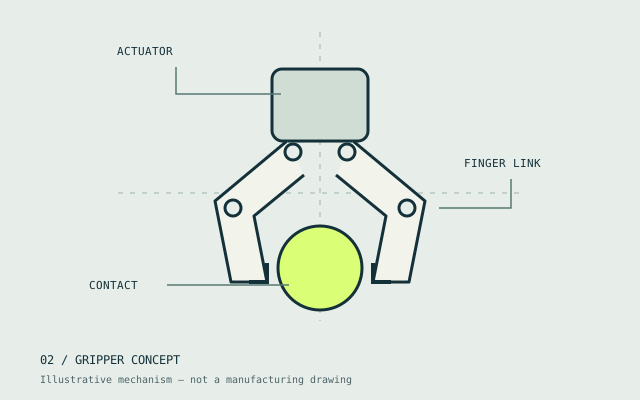
A compact gripper prototype built to compare finger geometry and contact behaviour on objects of different shapes.
CAD
3D printing
Arduino
Force sensing
Context
Rigid fingertips made contact unevenly and pushed lightweight objects out of the grip.
Objective
Explore a compliant finger design within the existing actuator and manufacturing constraints.
My contribution
I modelled interchangeable fingers, printed prototypes and photographed their contact patterns. A simple force-sensor fixture helped compare iterations under the same conditions.
Outcome
The final report explained which shapes the design could hold and where the fingers still twisted. It included the CAD revisions and the limits of the test fixture.
Case 03Personal project
Sensor-to-motion integration
My role Firmware & system documentation
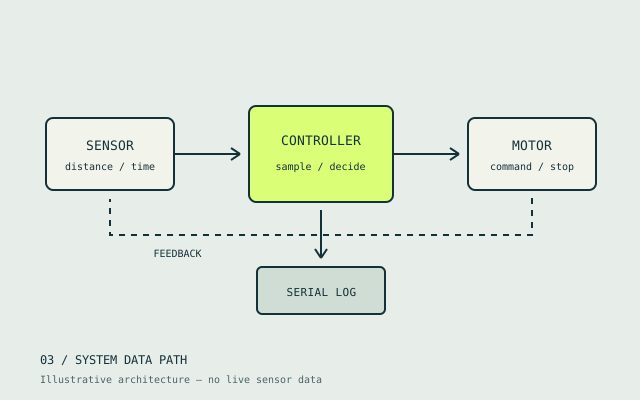
An integration exercise tracing a distance measurement from the sensor driver to a motor command, with a visible stop condition.
C++
Microcontroller
Serial logging
Context
A working sensor driver and motor driver did not yet form a predictable complete system.
Objective
Define the data path and document how the controller handles stale or missing readings.
My contribution
I separated sampling from motor updates, added timestamped logs, and exercised the stop condition with disconnected and delayed sensor inputs.
Outcome
The write-up links each state transition to an observed log sequence. Further work would test the same behaviour under processor load.
02 / Approach
Behind the work
I enjoy the handover between disciplines: turning a mechanical limit into a control decision, or using a log to explain unexpected motion. My project notes show what I owned, what the team built together, and what I would investigate next.
Tools & capabilities
ROS 2
Python
C++
Navigation
Sensor integration
CAD
Embedded control
Experiment planning
Technical writing
Team integration
03 / Experience
Where I have worked
2024 — 2025
Student robotics team member
University robotics society
Worked with mechanical and software teammates on an indoor rover.
Owned navigation configuration and integration notes.
Helped plan shared test sessions and recorded unresolved issues for handover.
Student team
Systems integration
04 / Background
Learning & credentials
2022 — 2025
BEng Robotics Engineering
Example University
Final-year project: indoor navigation rover
Coursework in control, mechanics and embedded systems