Case 01Final-year team project
Indoor navigation rover
My role Navigation & integration
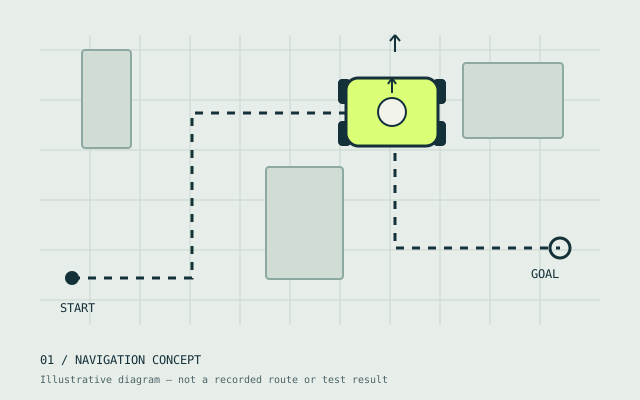
A student rover project exploring localisation and repeatable navigation in a changing indoor route.
- Context
- The team could drive the rover manually, but it lost track of its position when a wheel slipped or the corridor layout changed.
- Objective
- Connect localisation, route planning and motion control, then make the failure cases understandable to the next team.
- My contribution
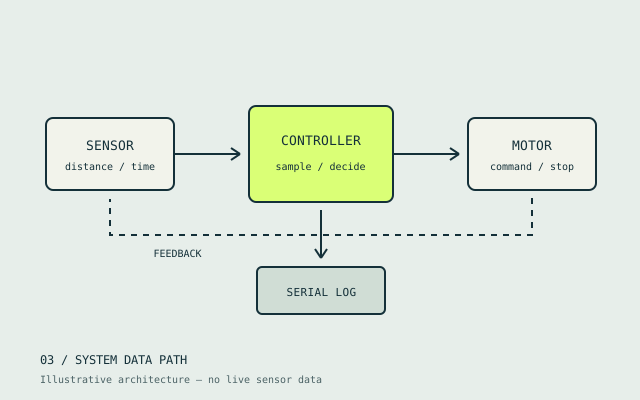
- I integrated the encoder and lidar inputs, checked coordinate frames, and wrote a repeatable route procedure. Recorded runs helped separate localisation errors from controller tuning problems.
- Outcome
- The project handover included route recordings, configuration notes and examples of recovery failures. Reflective surfaces remained an open issue for the next iteration.